2026Finalist
HW · Tap2ETH
ETHGlobal Mumbai 2026
Turns your existing bank card into an Ethereum hardware wallet that works at POS terminals. Also won Uniswap Foundation (4th) and Whitechain Stablecoin Payments (2nd).
 Log
01 / Jovian Dsouza
I'm an engineer who has spent the last few years shipping production systems: on-device AI for Galaxy flagships at Samsung R&D, and high-stakes backend infrastructure at CoinDCX.
My roots are in robotics: ROS navigation and manipulation, drones, a hand-built 3D printer and AI agents. Now I'm going all-in on physical AI, building robots that learn in simulation and have understanding of the real world.
I’m at my best when I can own the entire stack, hardware, firmware, models, and the software. I’ve taken this approach to winning hackathons, shipping complete products from prototype to working system.
Interests
Education
2018 — 2022
National Institute of Technology, Goa
B.Tech, Computer Science & Engineering
CGPA 9.13 / 10 · GenAI, LLMs and Robotics
HW · Tap2ETH
Turns your existing bank card into an Ethereum hardware wallet that works at POS terminals. Also won Uniswap Foundation (4th) and Whitechain Stablecoin Payments (2nd).
Log HW · UthaLe Robotics
A mobile manipulator that walks dark-store aisles, picks ordered items and delivers them to the order box.
 Log
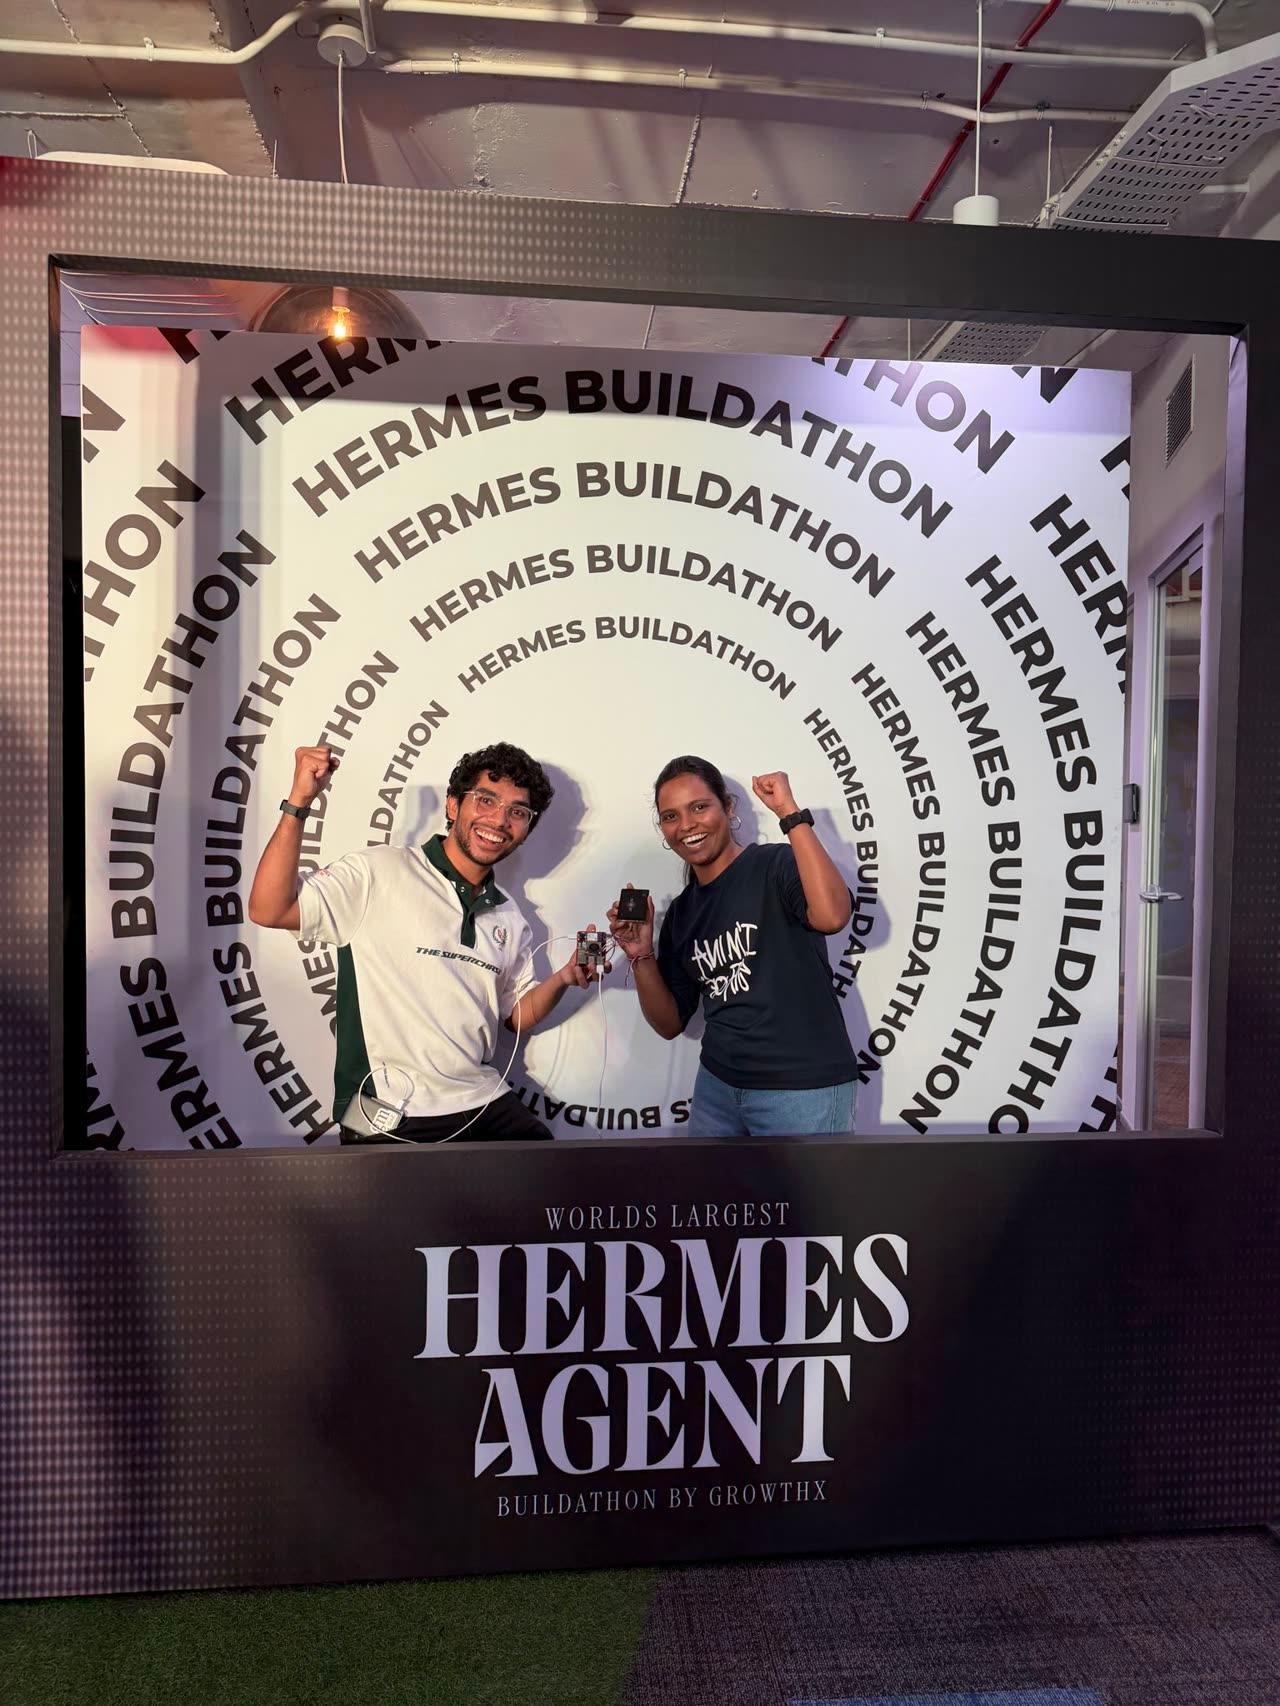
HW · Hermes on Pi
A Hermes agent running on a Raspberry Pi that drives a phone app end-to-end.
 Log
HW · Better Wallet
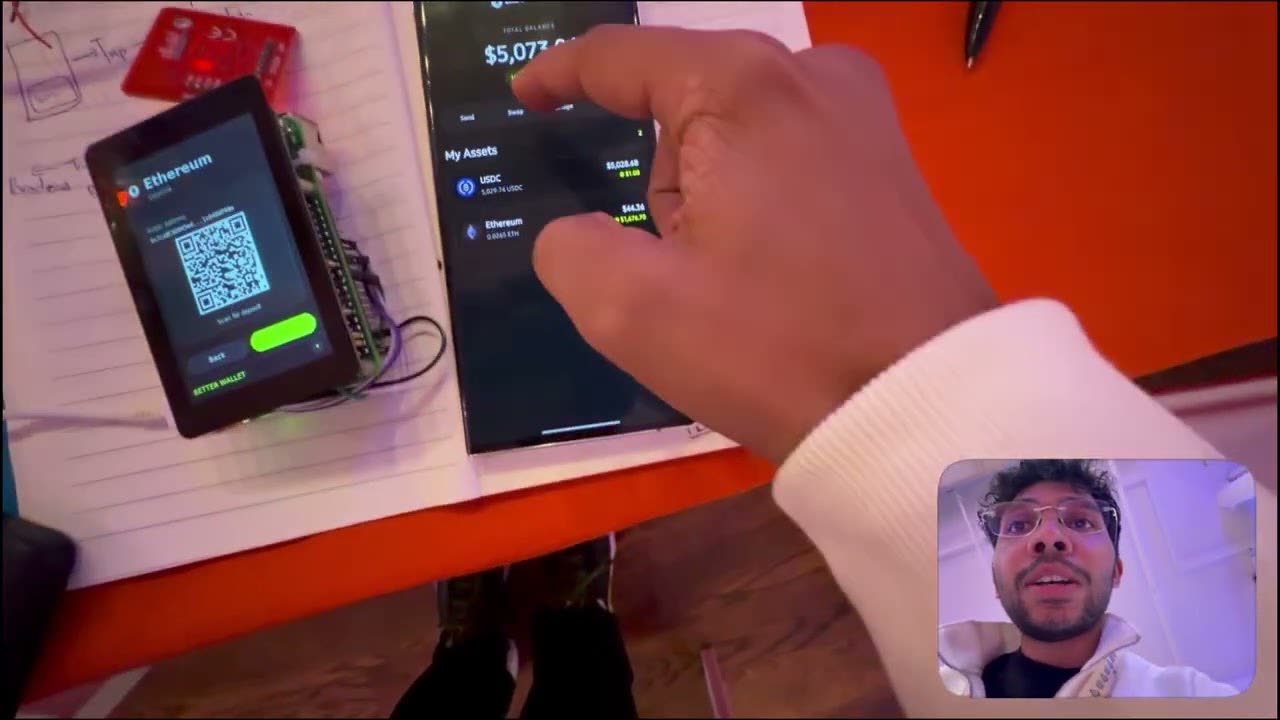
Air-gapped signing that later became a DIY Raspberry Pi + NFC hardware wallet.
 Log
Global Finalist
ETH Arcade · 2026
3rd
PocketFM GenAI Media Hackathon
Apollo7 · 2026
2nd
Colosseum Network State Bounty
Better Wallet Hardware · 2026
2nd
Better Wallet App · 2025
2nd
Bonkathon · Consumer Apps
Picoplay · 2024
2nd
Blinkathon
AskAnon · 2024
01
Oct 2024 — Present
Bangalore
Rust / Go / TypeScript / Kubernetes / PostgreSQL / AWS
02
Feb 2022 — Sep 2024
Bangalore
Python / PyTorch / TensorFlow / On-device ML / Android / Bazel
03
Jan 2021 — Feb 2022
San Francisco (Remote)
Python / PyTorch / Pytorch Lightning / 3D-CNNs / Yolo
telemetry offline — contribution data unavailable
Goals
0
Behaviours
Servos · hip / knee
| FL l1/l3 | — | — |
|---|---|---|
| FR r1/r3 | — | — |
| BL l2/l4 | — | — |
| BR r2/r4 | — | — |
pos —
Molty's real CAD model (from the open Sesame robot) running the firmware's servo keyframes. Its locomotion policy is trained with PPO in MuJoCo.